A Decade of Learning-Based Control: From Theoretic Foundations to Practical Deployment
CDC, 2026
Conference
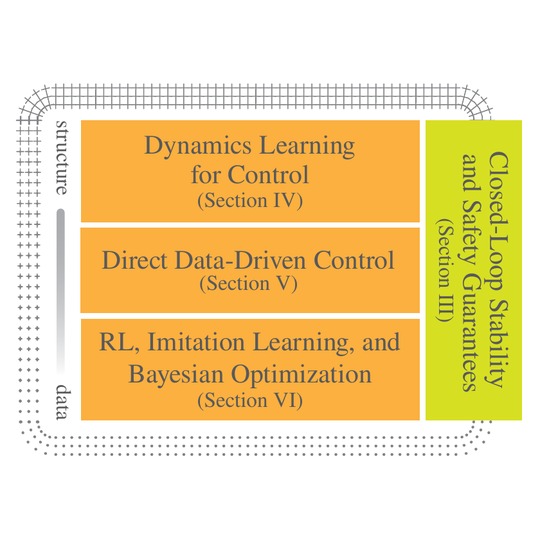
Tutorial marking ten years of CDC Learning-Based Control sessions, covering stability and safety foundations, dynamics learning, data-driven control, and RL/IL/BO, with open-source examples.
An introductory guide, marking ten years of dedicated conference sessions, on how robots and other machines can learn from data and experience while staying stable and safe, with open-source code.